Chang Won (John) Lee
Hi there! I'm a 2nd-year PhD student at the University of Toronto, advised by Professor Steven Waslander
in the Toronto Robotics and AI Lab.
I am affiliated with University of Toronto Robotics Institute and
Vector Institute.
I obtained my Master's and Bachelor's degrees from the University of Toronto, with a Bachelor's in Engineering Science (Machine Intelligence major).
My research focuses on generalist robots that can follow open-ended instructions reliably in open-world settings.
I am interested in task decomposition and reasoning, long-horizon embodied task planning, agent orchestration, generalist vision-language-action (VLA) policies, and learning from experience (continual and incremental learning).
Previously, I worked on uncertainty quantification, multi-object tracking, and visual anomaly detection for autonomous driving and space robotics.
CV
Github
G. Scholar
LinkedIn
Please don't hesitate to reach out if you have any questions or would like to chat!
john [dot] lee [at] robotics [dot] utias [dot] utoronto [dot] ca
PhD in Aerospace Engineering and Robotics
University of Toronto
September 2025 - Present
Advisor: Professor Steven Waslander
Master of Applied Science in Aerospace Engineering and Robotics
University of Toronto
September 2023 - September 2025
Advisor: Professor Steven Waslander
Bachelor of Applied Science in Engineering Science (Machine Intelligence)
University of Toronto
September 2018 - June 2023
Thesis Advisor: Professor Steven Waslander
DistillPlan: Distilling Episodes into Decomposition Schemas for Efficient Long-Horizon Embodied Task Planning
Chang Won Lee, M. Yuan, Steven L. Waslander
Under Review
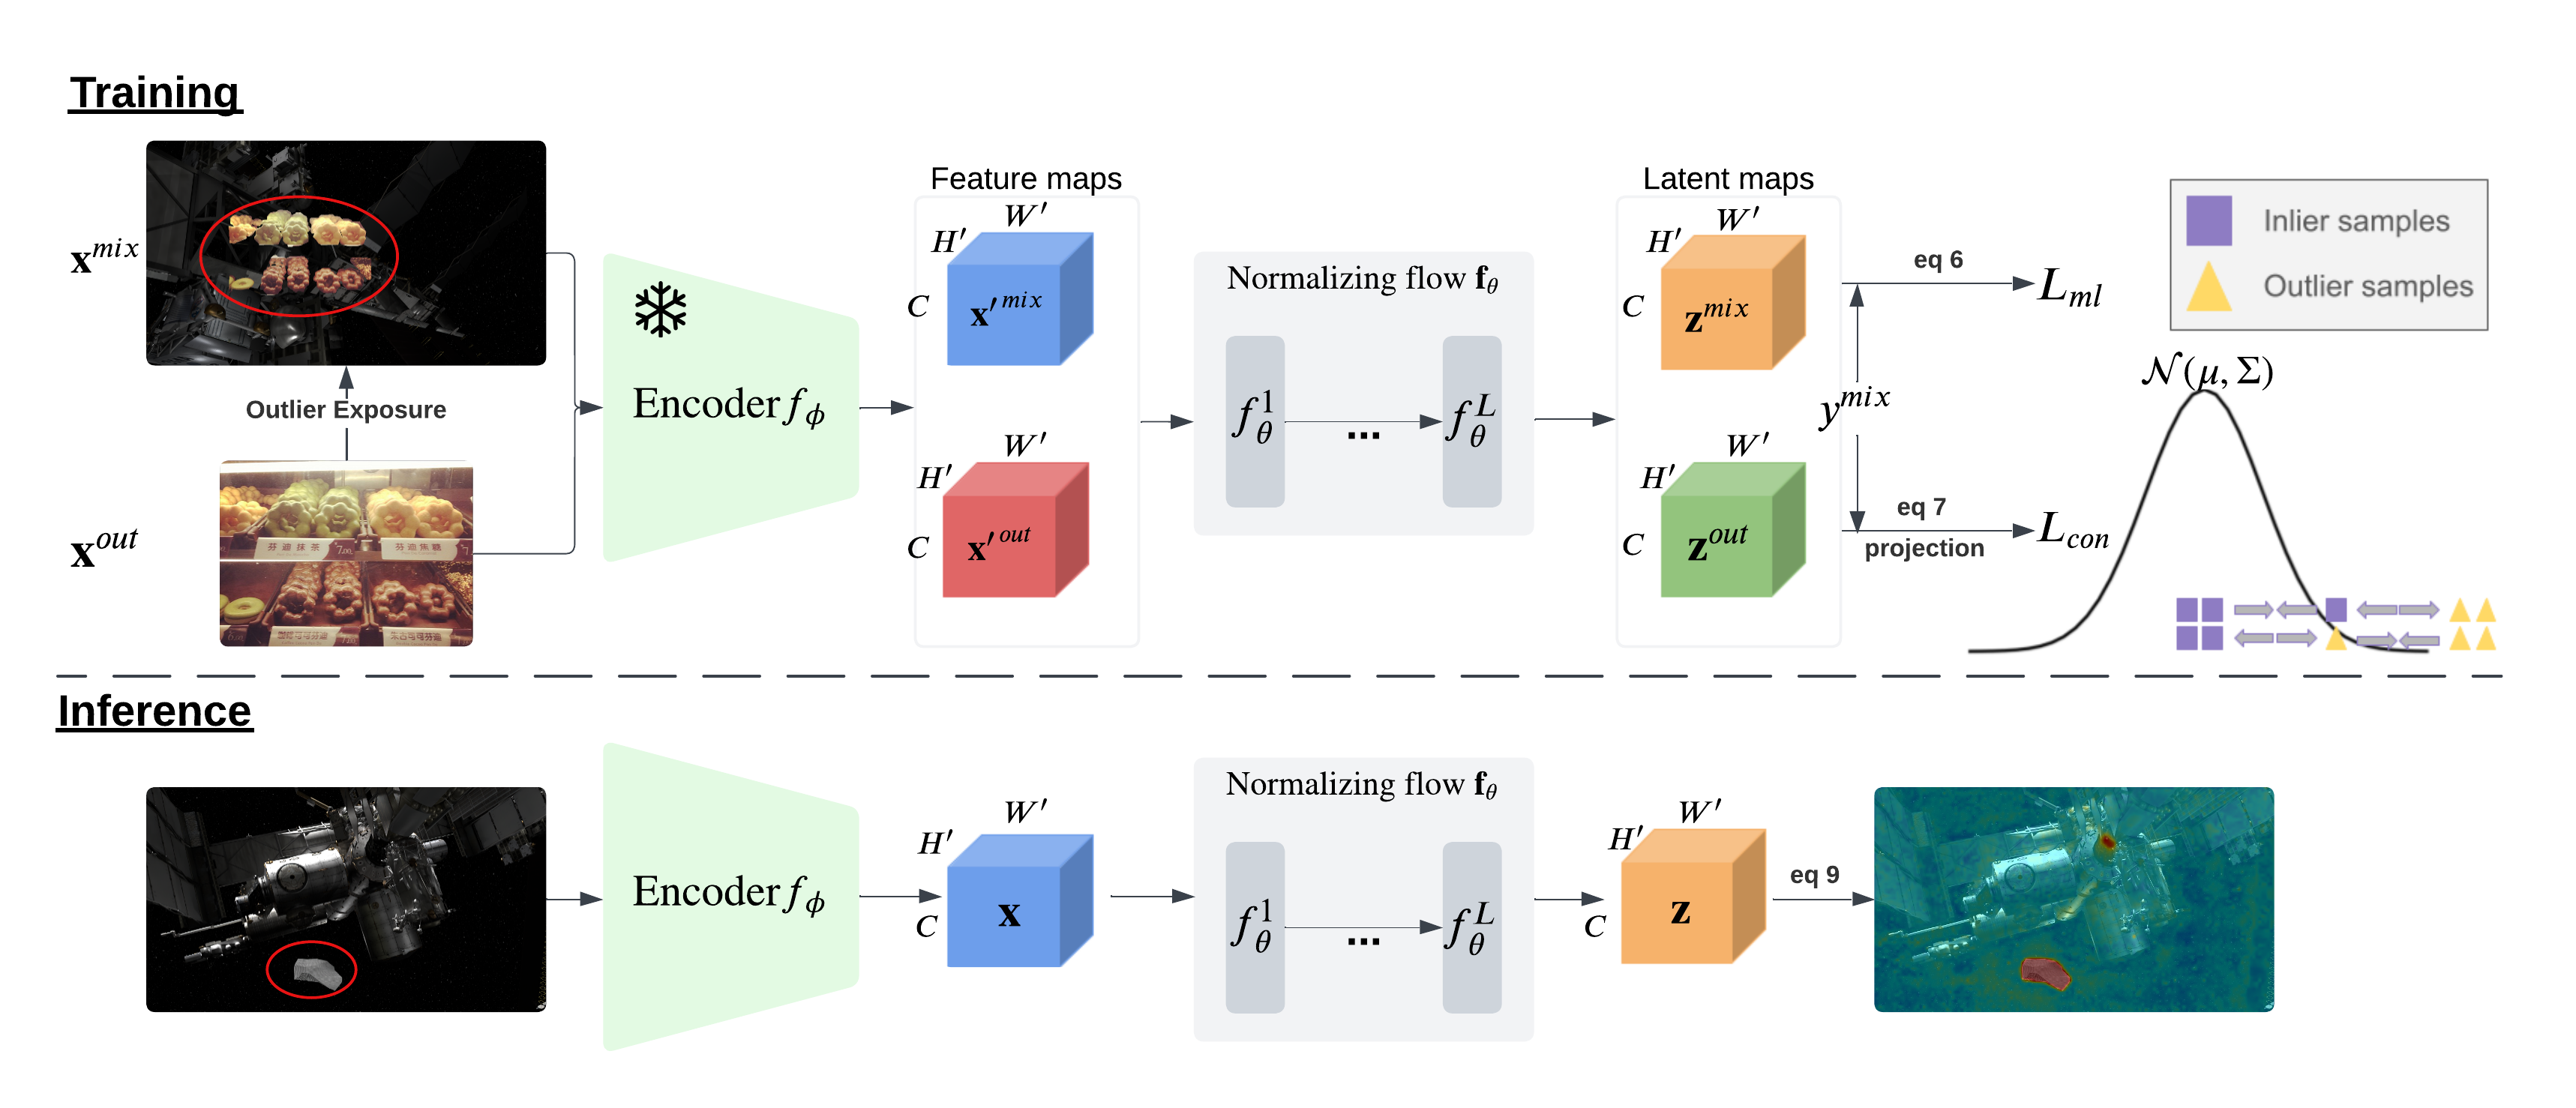
FlowCLAS: Enhancing Normalizing Flow-Based Anomaly Segmentation Via Contrastive Learning
Chang Won Lee, Selina Leveugle, Paul Grouchy, Chris Langley, Svetlana Stolpner, Jonathan Kelly, Steven L. Waslander
IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2026
Webpage •
Paper
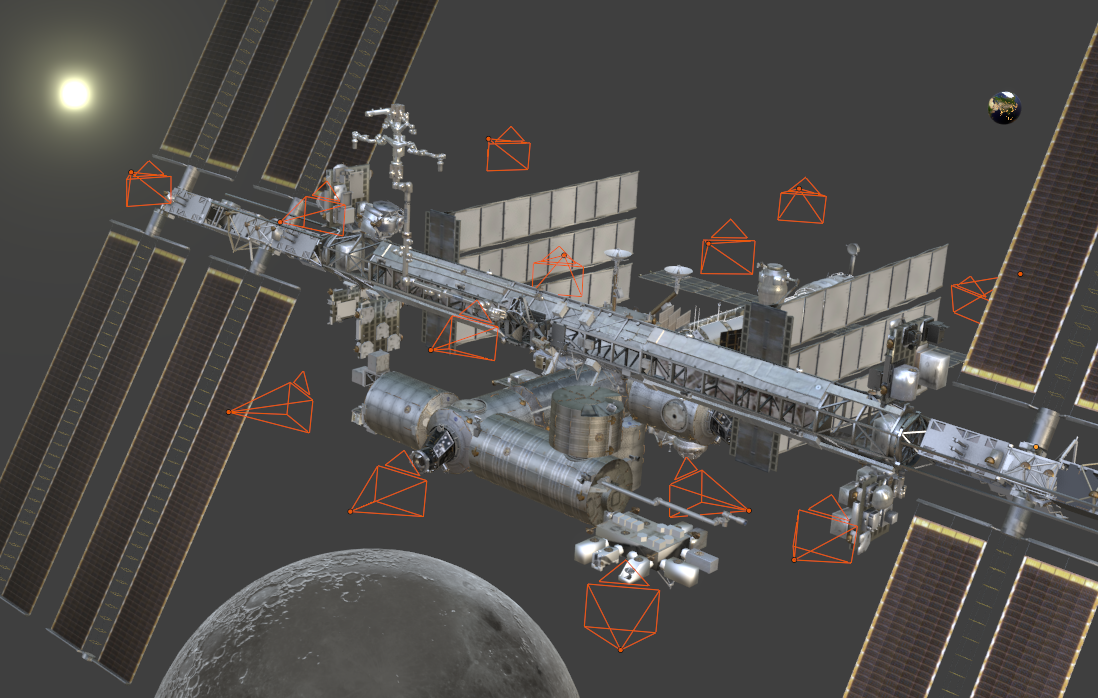
A Photorealistic Dataset and Vision-Based Algorithm for Anomaly Detection During Proximity Operations in Lunar Orbit
Selina Leveugle, Chang Won Lee, Svetlana Stolpner, Chris Langley, Paul Grouchy, Steven L. Waslander, Jonathan Kelly
IEEE Robotics and Automation Letters (RA-L), 2026
Paper •
Code
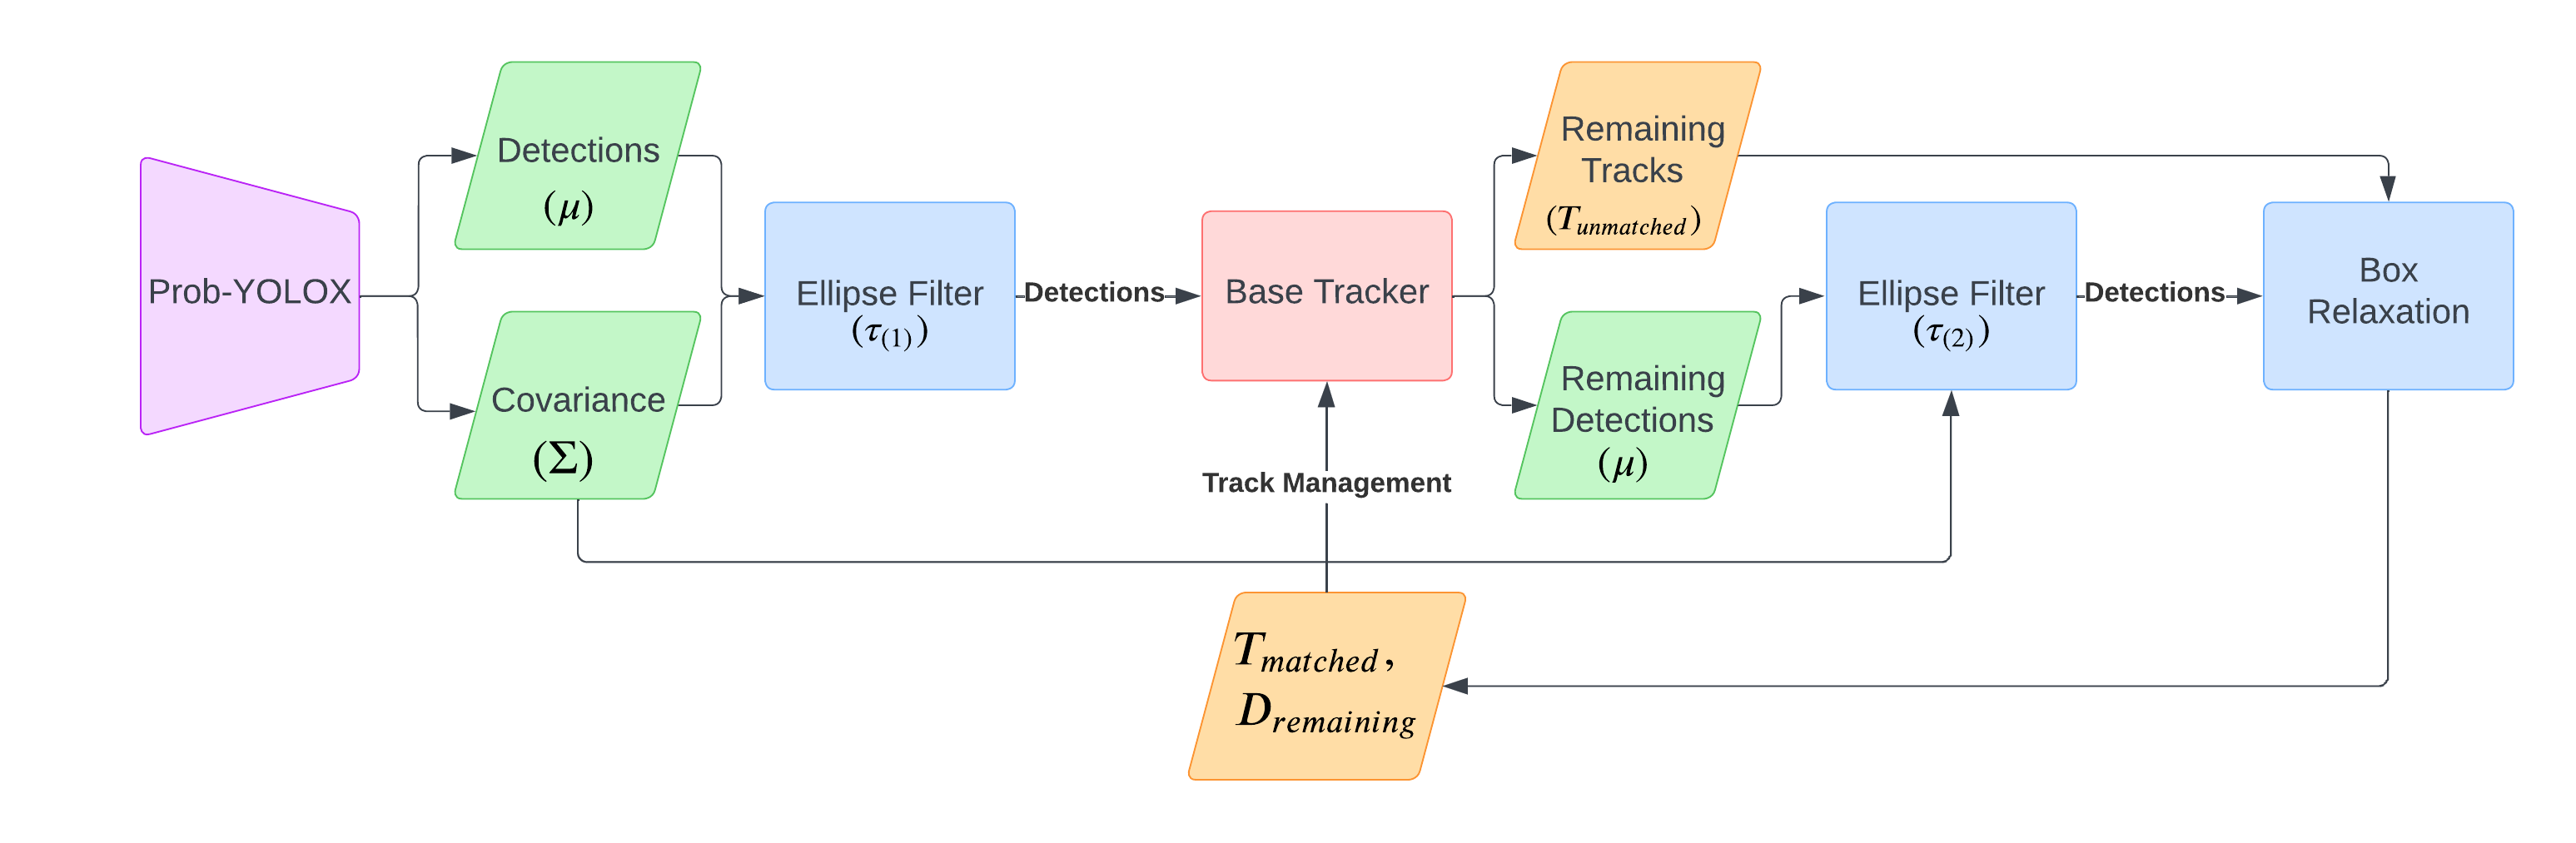
UncertaintyTrack: Exploiting Detection and Localization Uncertainty in Multi-Object Tracking
Chang Won Lee, Steven L. Waslander
2024 IEEE International Conference on Robotics and Automation (ICRA)
Paper •
Code
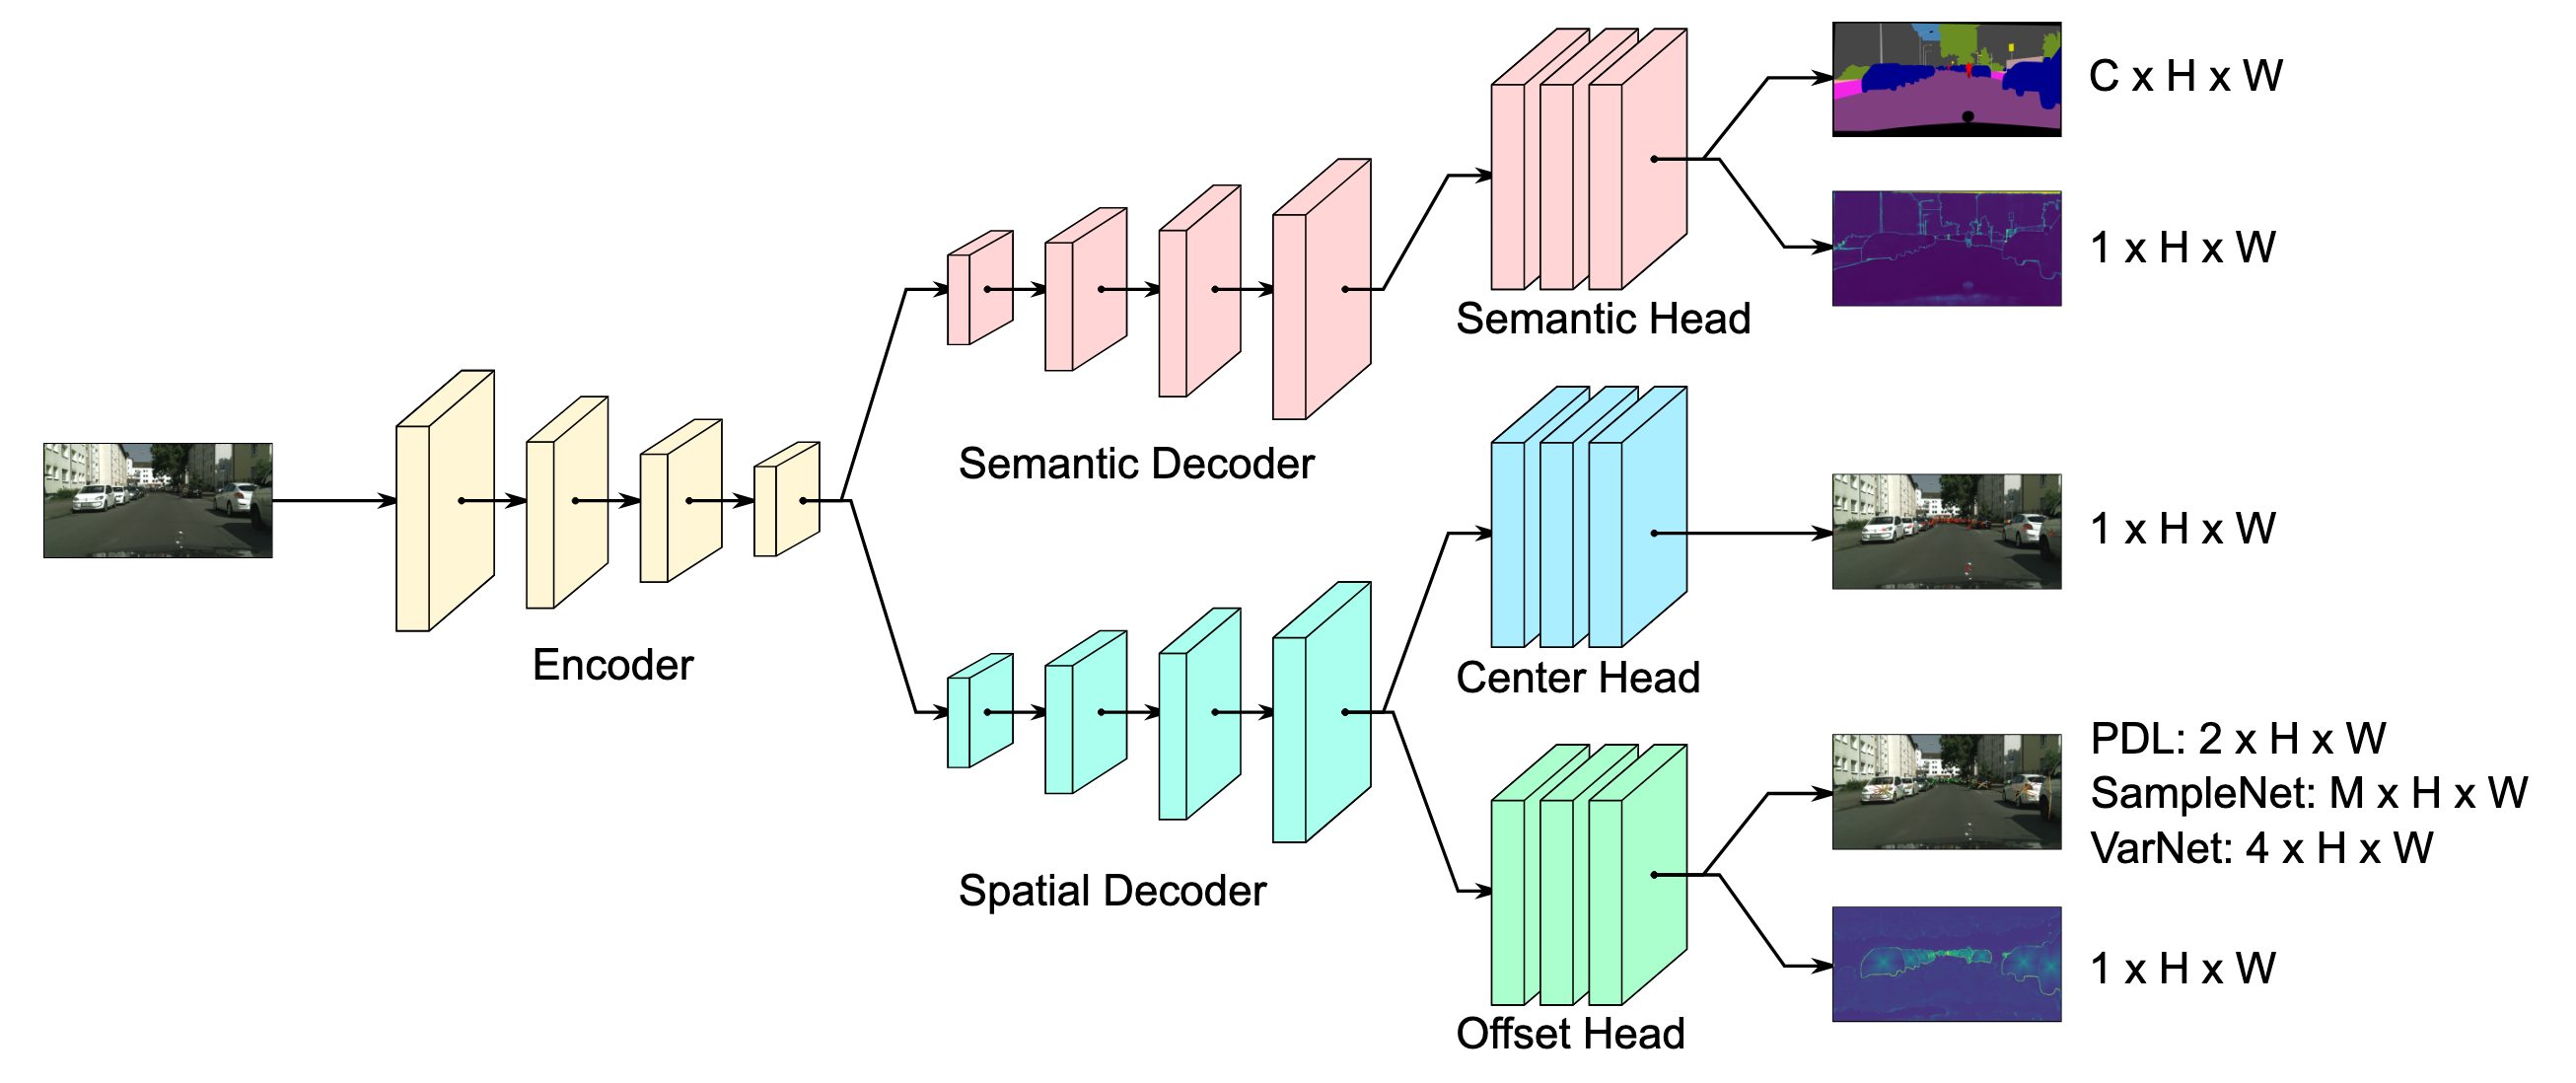
ProPanDL: A Modular Architecture for Uncertainty-Aware Panoptic Segmentation
Jacob Deery, Chang Won Lee, Steven Waslander
2023 20th Conference on Robots and Vision (CRV)
Paper
2026
Teaching Assistant for Robotics Capstone Design (ROB498)2025
Teaching Assistant for Mathematics for Robotics (ROB310)2025
Teaching Assistant for Artificial Intelligence (ROB311)2024
Teaching Assistant for Introduction to Mobile Robotics (CSC477)2024
Teaching Assistant for Mathematics for Robotics (ROB310)2023
Teaching Assistant for Mathematics for Robotics (ROB310)2022
Teaching Assistant for Linear Algebra for Engineering (MAT188)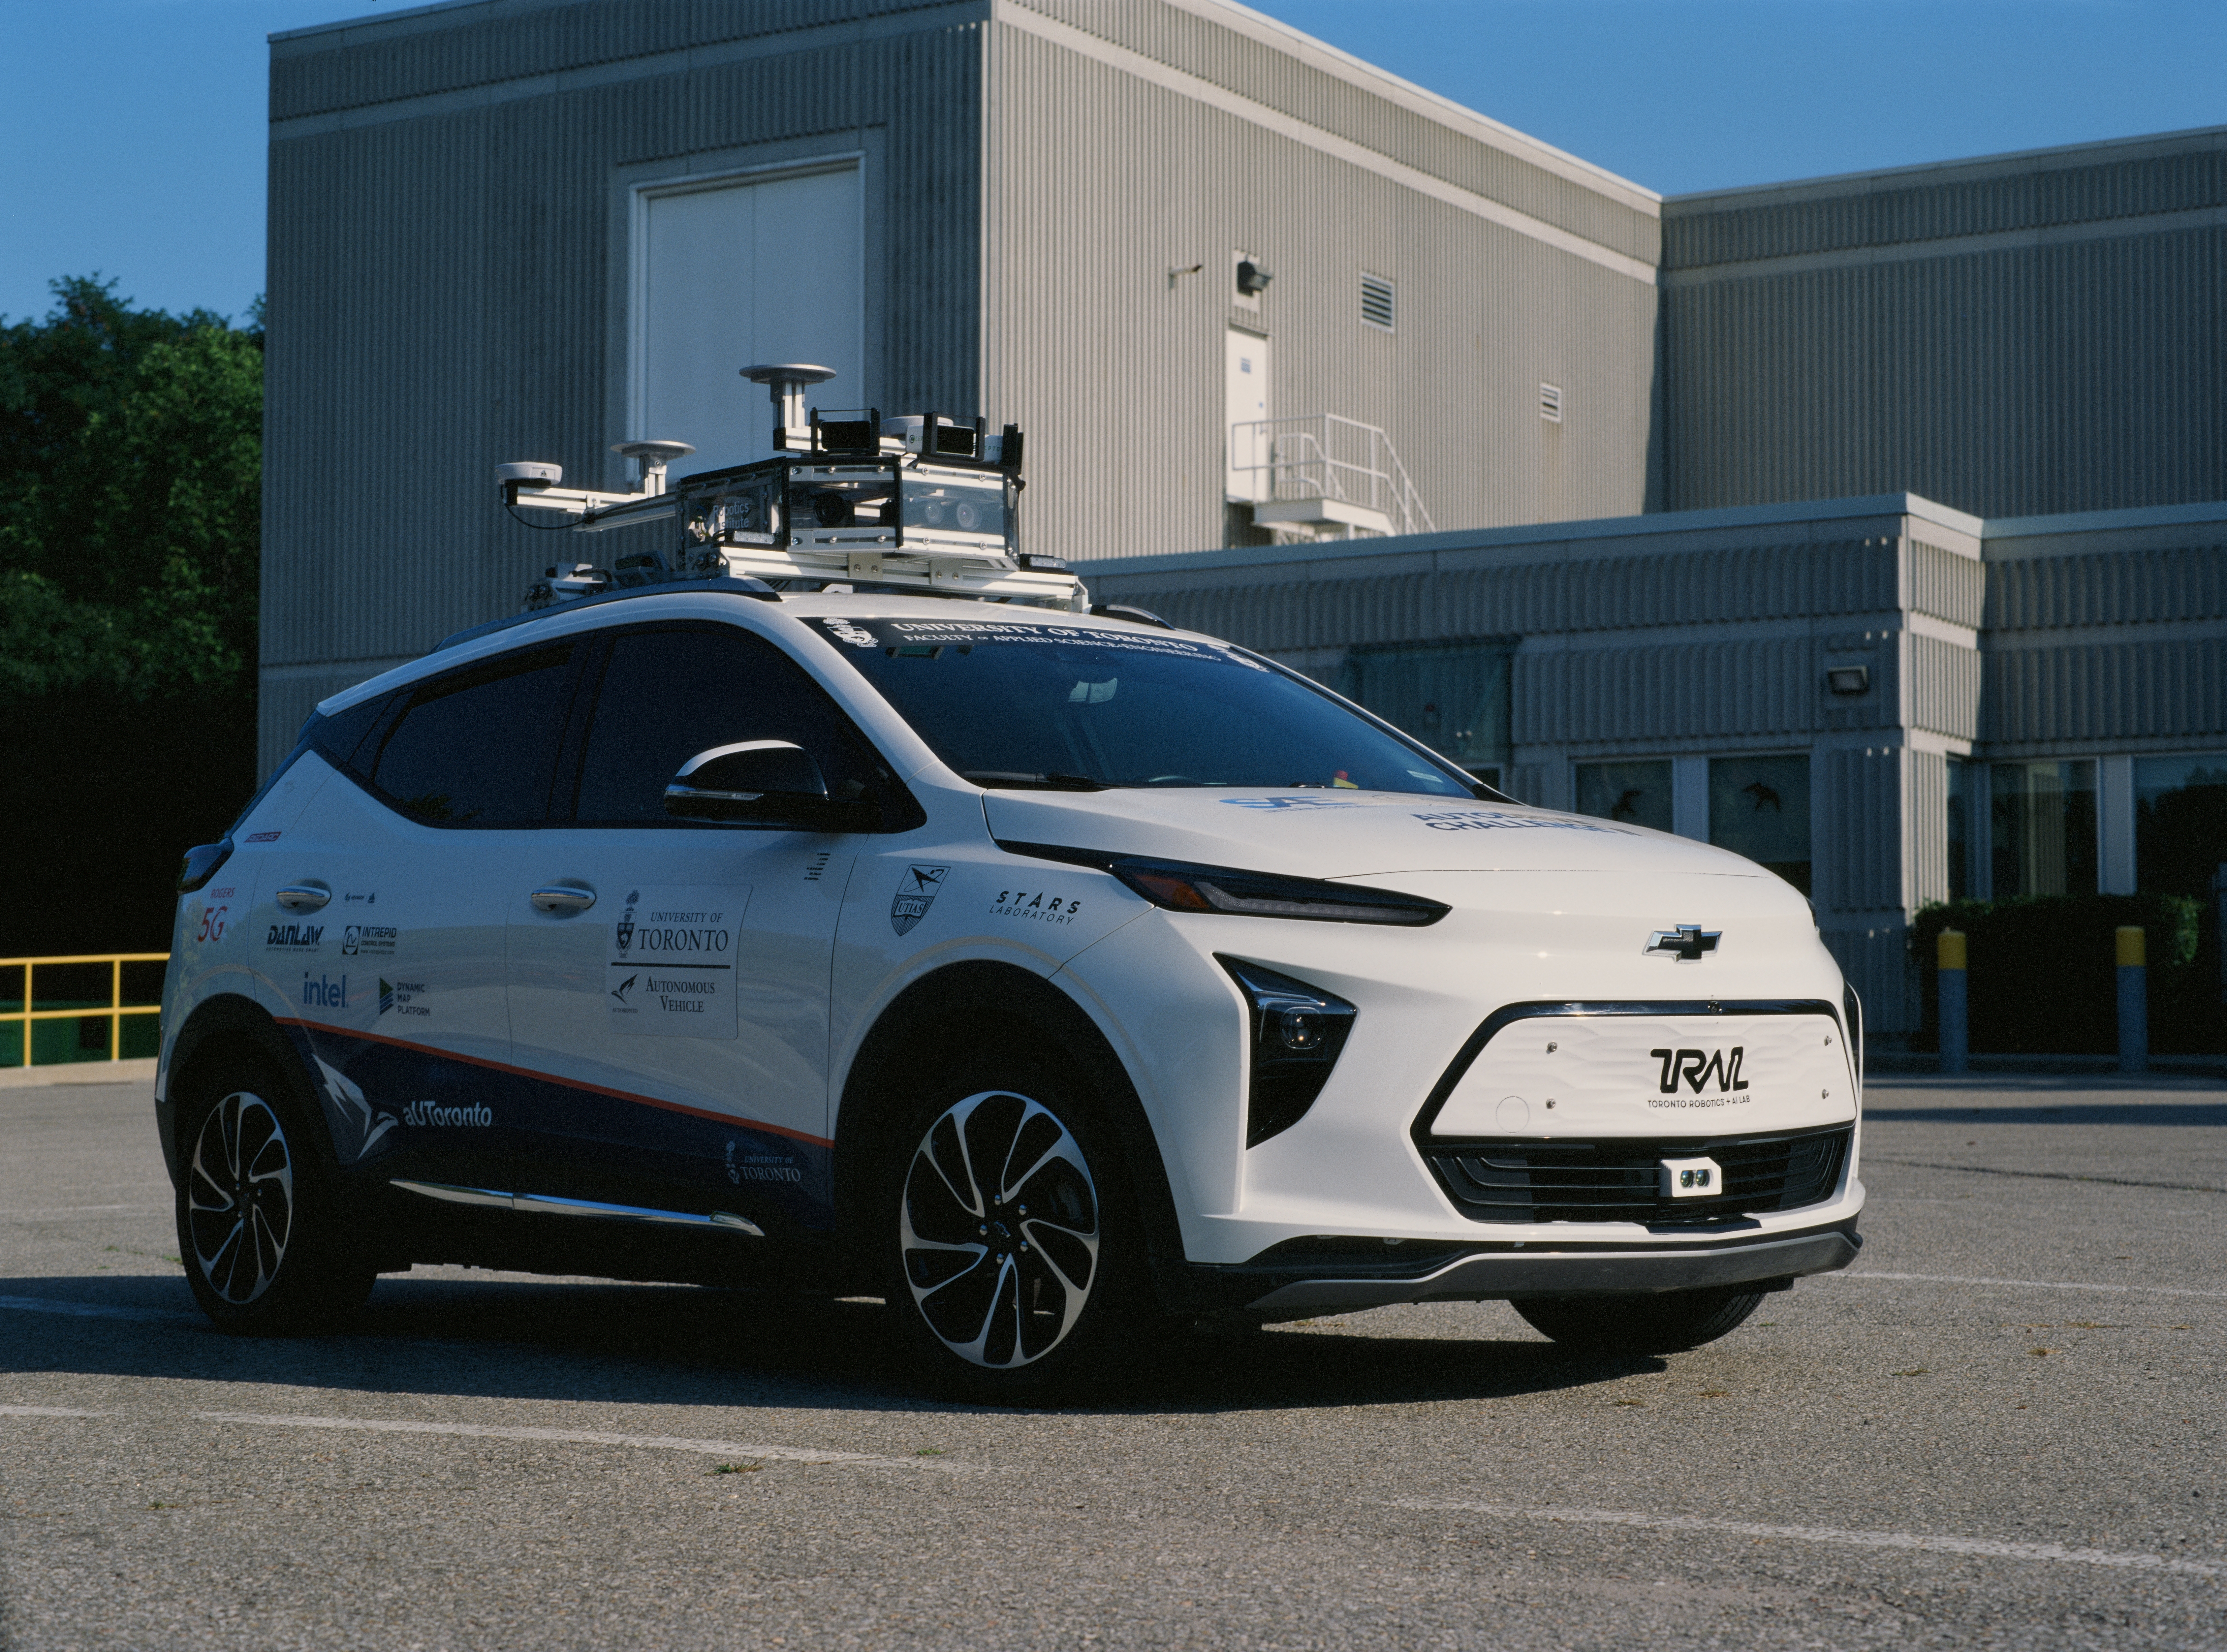
Software Engineer (General Member) at aUToronto (August 2021 - April 2023)
University of Toronto's self-driving car team.
Our team won all dynamic and static challenges at the SAE AutoDrive Challenge II in 2024.
2019 - 2022
University of Toronto Engineering Student Ambassador2020 - 2021
University of Toronto Engineering Student Mentor2021
Engineering Science Education Conference (ESEC) Web Designer & Organizer